New York Tech Media
  • News
  • FinTech
  • AI & Robotics
  • Cybersecurity
  • Startups & Leaders
  • Venture Capital
No Result
View All Result
  • News
  • FinTech
  • AI & Robotics
  • Cybersecurity
  • Startups & Leaders
  • Venture Capital
No Result
View All Result
New York Tech Media
No Result
View All Result
Home AI & Robotics

Exploring ROS2 with a wheeled robot – #4 – Obstacle avoidance

New York Tech Editorial Team by New York Tech Editorial Team
December 6, 2021
in AI & Robotics
0
Exploring ROS2 with a wheeled robot – #4 – Obstacle avoidance
Share on FacebookShare on Twitter

By Marco Arruda

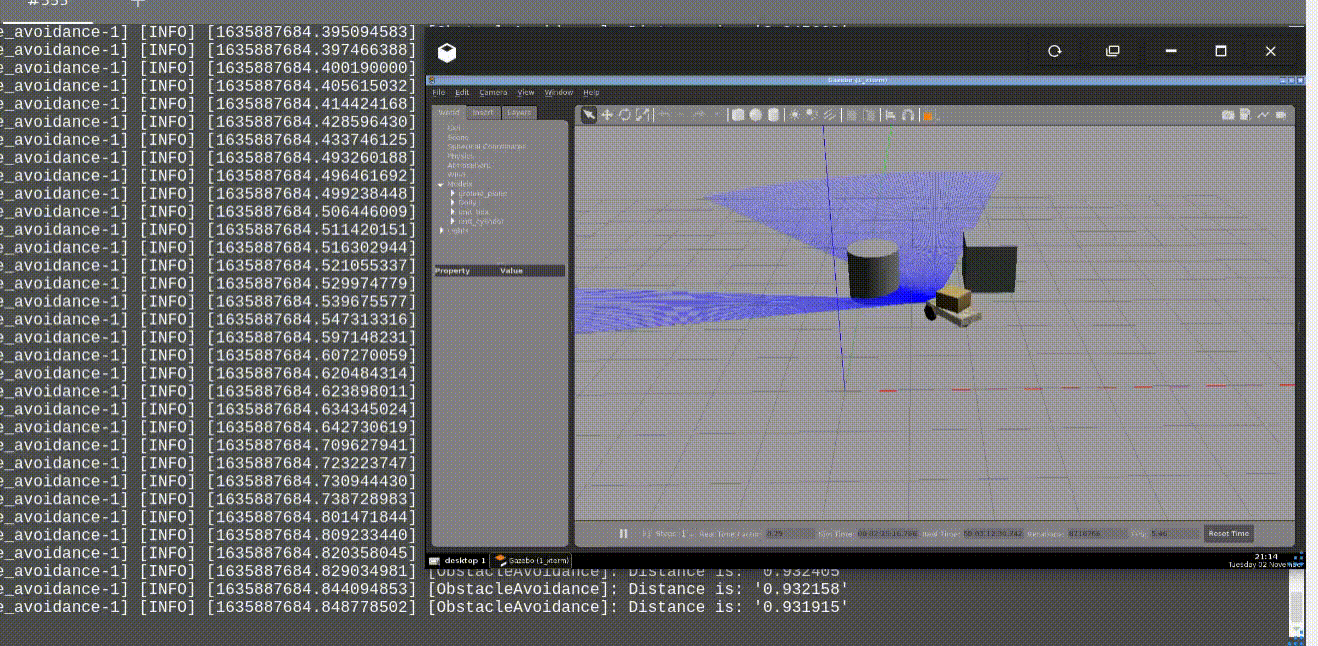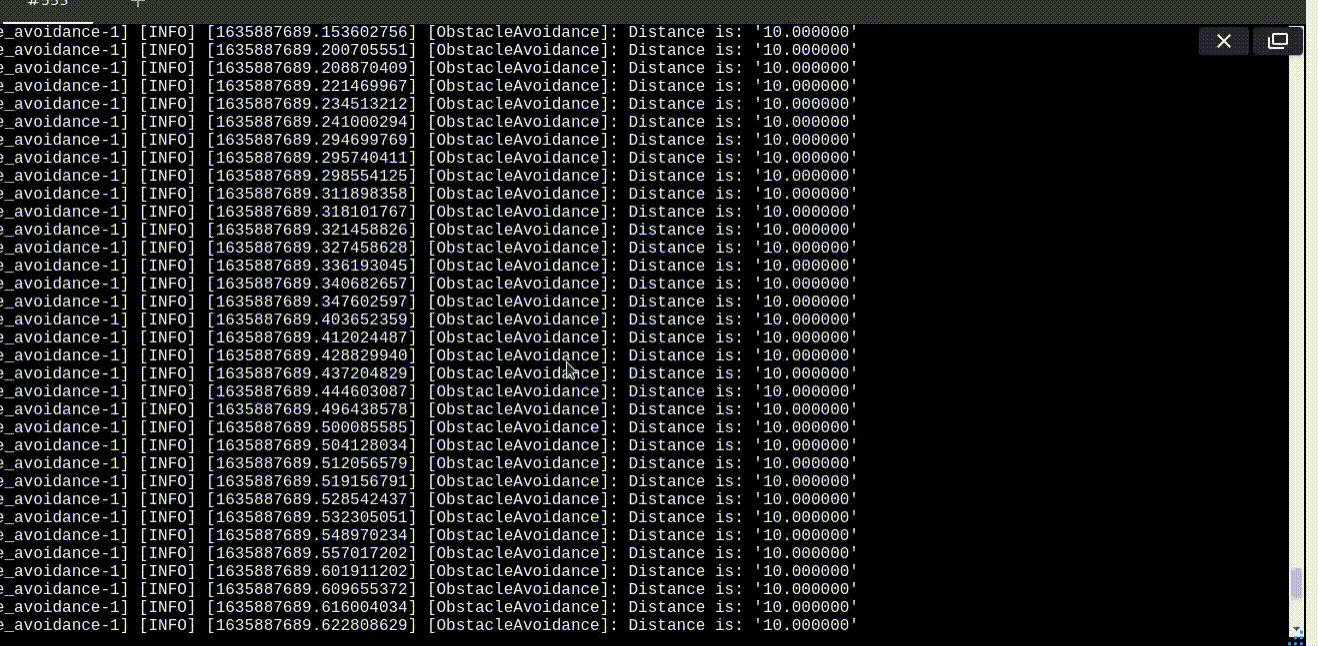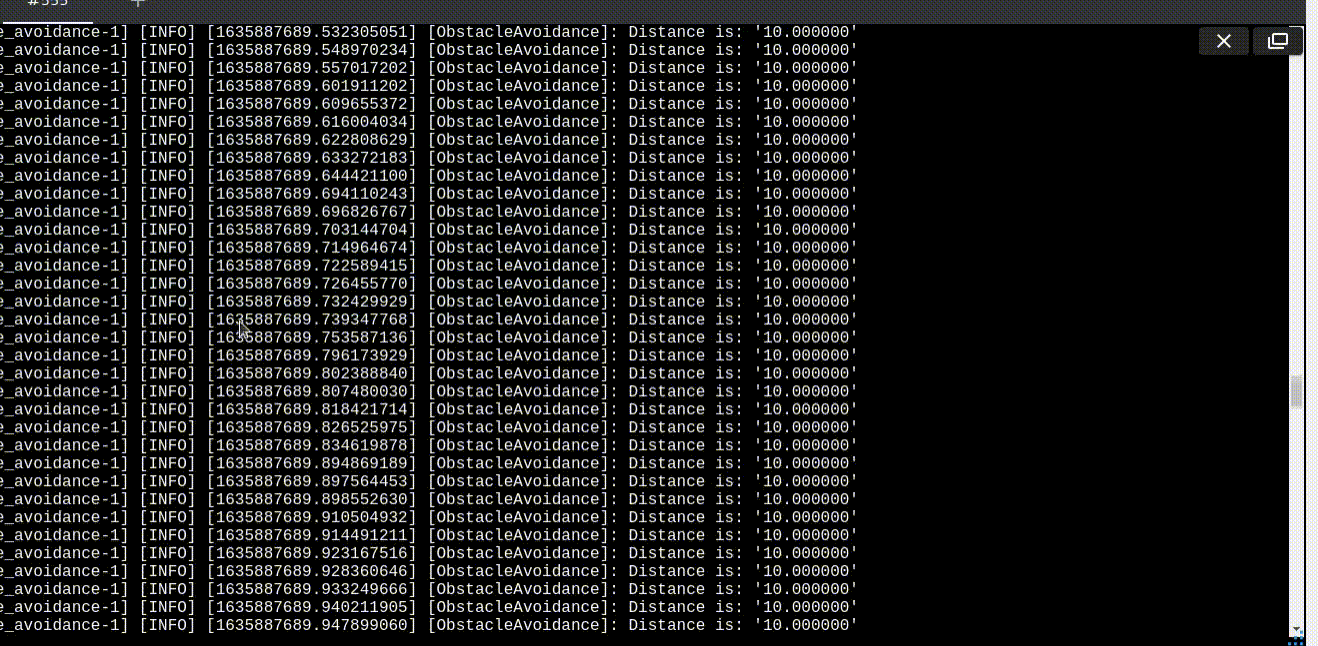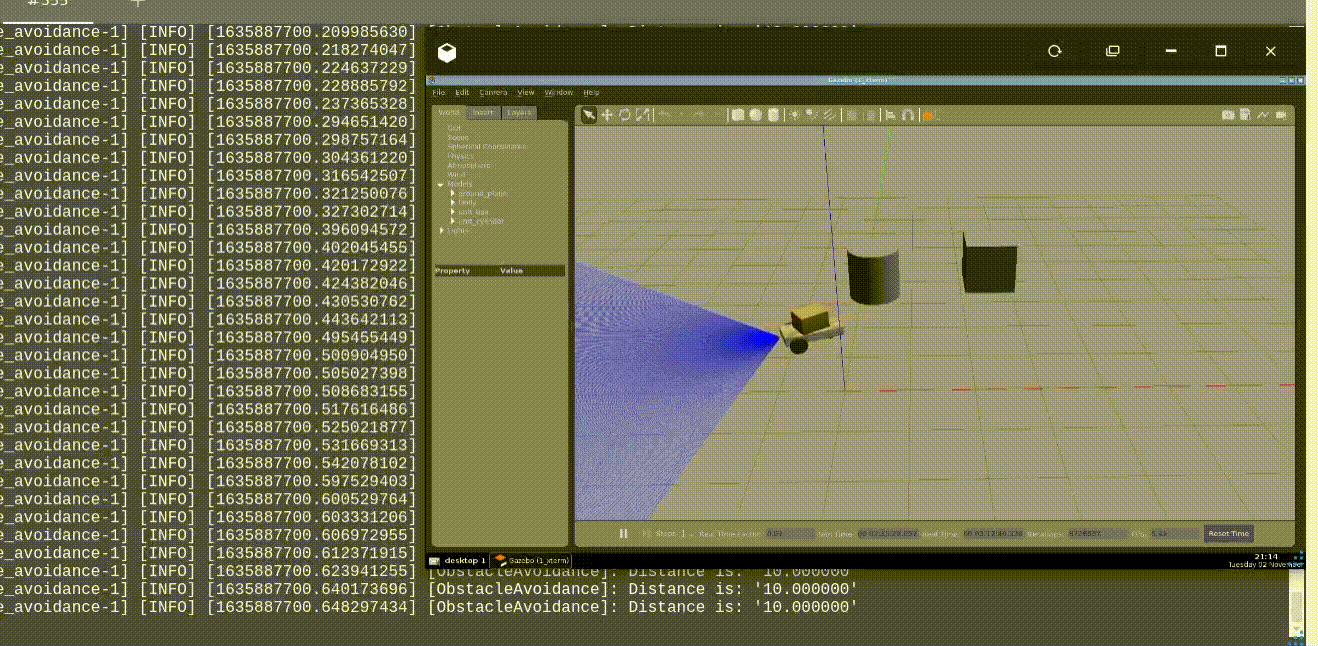
In this post you’ll learn how to program a robot to avoid obstacles using ROS2 and C++. Up to the end of the post, the Dolly robot moves autonomously in a scene with many obstacles, simulated using Gazebo 11.

You’ll learn:

  • How to publish AND subscribe topics in the same ROS2 Node
  • How to avoid obstacles
  • How to implement your own algorithm in ROS2 and C++

1 – Setup environment – Launch simulation

Before anything else, make sure you have the rosject from the previous post, you can copy it from here.

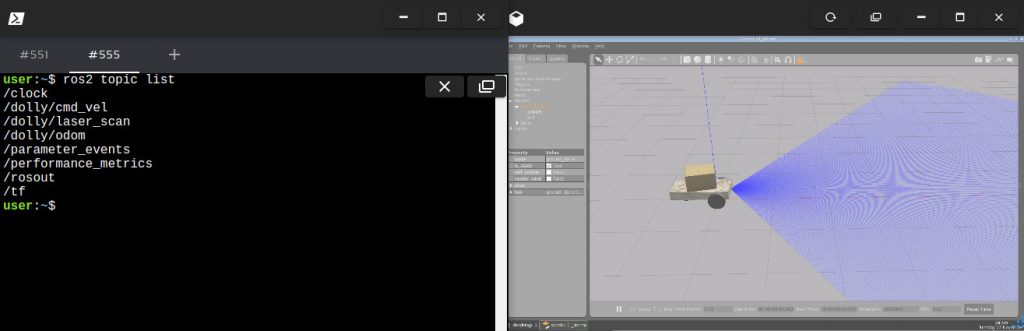
Launch the simulation in one webshell and in a different tab, checkout the topics we have available. You must get something similar to the image below:
2 – Create the node

In order to have our obstacle avoidance algorithm, let’s create a new executable in the file ~/ros2_ws/src/my_package/obstacle_avoidance.cpp:

#include "geometry_msgs/msg/twist.hpp"    // Twist
#include "rclcpp/rclcpp.hpp"              // ROS Core Libraries
#include "sensor_msgs/msg/laser_scan.hpp" // Laser Scan

using std::placeholders::_1;

class ObstacleAvoidance : public rclcpp::Node {
public:
  ObstacleAvoidance() : Node("ObstacleAvoidance") {

    auto default_qos = rclcpp::QoS(rclcpp::SystemDefaultsQoS());
    subscription_ = this->create_subscription(
        "laser_scan", default_qos,
        std::bind(&ObstacleAvoidance::topic_callback, this, _1));
    publisher_ =
        this->create_publisher("cmd_vel", 10);
  }

private:
  void topic_callback(const sensor_msgs::msg::LaserScan::SharedPtr _msg) {
    // 200 readings, from right to left, from -57 to 57 degress
    // calculate new velocity cmd
    float min = 10;
    for (int i = 0; i < 200; i++) { float current = _msg->ranges[i];
      if (current < min) { min = current; } } 
    auto message = this->calculateVelMsg(min);
    publisher_->publish(message);
  }
  geometry_msgs::msg::Twist calculateVelMsg(float distance) {
    auto msg = geometry_msgs::msg::Twist();
    // logic
    RCLCPP_INFO(this->get_logger(), "Distance is: '%f'", distance);
    if (distance < 1) {
      // turn around
      msg.linear.x = 0;
      msg.angular.z = 0.3;
    } else {
      // go straight ahead
      msg.linear.x = 0.3;
      msg.angular.z = 0;
    }
    return msg;
  }
  rclcpp::Publisher::SharedPtr publisher_;
  rclcpp::Subscription::SharedPtr subscription_;
};

int main(int argc, char *argv[]) {
  rclcpp::init(argc, argv);
  rclcpp::spin(std::make_shared());
  rclcpp::shutdown();
  return 0;
}

In the main function we have:

  • Initialize node rclcpp::init
  • Keep it running rclcpp::spin

Inside the class constructor:

  • Subcribe to the laser scan messages: subscription_
  • Publish to the robot diff driver: publisher_

The obstacle avoidance intelligence goes inside the method calculateVelMsg. This is where decisions are made based on the laser readings. Notice that is depends purely on the minimum distance read from the message.

If you want to customize it, for example, consider only the readings in front of the robot, or even check if it is better to turn left or right, this is the place you need to work on! Remember to adjust the parameters, because the way it is, only the minimum value comes to this method.

3 – Compile the node

This executable depends on both geometry_msgs and sensor_msgs, that we have added in the two previous posts of this series. Make sure you have them at the beginning of the ~/ros2_ws/src/my_package/CMakeLists.txt file:

# find dependencies
find_package(ament_cmake REQUIRED)
find_package(rclcpp REQUIRED)
find_package(geometry_msgs REQUIRED)
find_package(sensor_msgs REQUIRED)

And finally, add the executable and install it:

# obstacle avoidance
add_executable(obstacle_avoidance src/obstacle_avoidance.cpp)
ament_target_dependencies(obstacle_avoidance rclcpp sensor_msgs geometry_msgs)

...

install(TARGETS
  reading_laser
  moving_robot
  obstacle_avoidance
  DESTINATION lib/${PROJECT_NAME}/
)

Compile the package:
colcon build --symlink-install --packages-select my_package

4 – Run the node

In order to run, use the following command:
ros2 run my_package obstacle_avoidance

It will not work for this robot! Why is that? We are subscribing and publishing to generic topics: cmd_vel and laser_scan.

We need a launch file to remap these topics, let’s create one at ~/ros2_ws/src/my_package/launch/obstacle_avoidance.launch.py:

from launch import LaunchDescription
from launch_ros.actions import Node

def generate_launch_description():

    obstacle_avoidance = Node(
        package="my_package",
        executable="obstacle_avoidance",
        output="screen",
        remappings=[
            ('laser_scan', '/dolly/laser_scan'),
            ('cmd_vel', '/dolly/cmd_vel'),
        ]
    )

    return LaunchDescription([obstacle_avoidance])


Recompile the package, source the workspace once more and launch it:
colcon build --symlink-install --packages-select my_package
source ~/ros2_ws/install/setup.bash
ros2 launch my_package obstacle_avoidance.launch.py
Related courses & extra links:

The post Exploring ROS2 with a wheeled robot – #4 – Obstacle Avoidance appeared first on The Construct.

The Construct Blog

Credit: Source link

Previous Post

Startup Toolkit for entrepreneurs: Paytm partners with Amazon Web Services

Next Post

The Fintech Revolution in China: Opportunities and Threats

New York Tech Editorial Team

New York Tech Editorial Team

New York Tech Media is a leading news publication that aims to provide the latest tech news, fintech, AI & robotics, cybersecurity, startups & leaders, venture capital, and much more!

Next Post
The Fintech Revolution in China: Opportunities and Threats

The Fintech Revolution in China: Opportunities and Threats

  • Trending
  • Comments
  • Latest
Meet the Top 10 K-Pop Artists Taking Over 2024

Meet the Top 10 K-Pop Artists Taking Over 2024

March 17, 2024
Clubhouse will soon let you pin links to the top of rooms

Clubhouse will soon let you pin links to the top of rooms

October 23, 2021
10 Raunchy Movies on Netflix You Won’t Regret Watching

10 Raunchy Movies on Netflix You Won’t Regret Watching

May 20, 2024
Panther for AWS allows security teams to monitor their AWS infrastructure in real-time

Many businesses lack a formal ransomware plan

March 29, 2022
Zach Mulcahey, 25 | Cover Story | Style Weekly

Zach Mulcahey, 25 | Cover Story | Style Weekly

March 29, 2022
How To Pitch The Investor: Ronen Menipaz, Founder of M51

How To Pitch The Investor: Ronen Menipaz, Founder of M51

March 29, 2022
Startups On Demand: renovai is the Netflix of Online Shopping

Startups On Demand: renovai is the Netflix of Online Shopping

2
Robot Company Offers $200K for Right to Use One Applicant’s Face and Voice ‘Forever’

Robot Company Offers $200K for Right to Use One Applicant’s Face and Voice ‘Forever’

1
Menashe Shani Accessibility High Tech on the low

Revolutionizing Accessibility: The Story of Purple Lens

1

Netgear announces a $1,500 Wi-Fi 6E mesh router

0
These apps let you customize Windows 11 to bring the taskbar back to life

These apps let you customize Windows 11 to bring the taskbar back to life

0
This bipedal robot uses propeller arms to slackline and skateboard

This bipedal robot uses propeller arms to slackline and skateboard

0
Guardz founders

Why Guardz Is Bringing Palo Alto Networks Prisma Browser Protection Into The MSP Security Stack

November 2, 2026
Hud Launches Agentic Rollouts to Give Coding Agents a Feedback Loop From Production

Hud Launches Agentic Rollouts to Give Coding Agents a Feedback Loop From Production

October 29, 2026
Pluto Security Emerges From Stealth With $42M in Funding After Building an AI Security Community

Pluto Security Shows Why Hugging Face Scanners Cleared a Live Malware Campaign

October 29, 2026
man sitting with legs crossed

Upwind’s $400M Series C Follows Fourfold Revenue Growth and a Jump to a $3.8B Valuation

October 28, 2026
Bloom Security and Cyera Turn Data Classification into Real-Time Enforcement at the Endpoint

Bloom Security and Cyera Turn Data Classification into Real-Time Enforcement at the Endpoint

October 22, 2026
Pluto Security Emerges From Stealth With $42M in Funding After Building an AI Security Community

Pluto Security Emerges From Stealth With $42M in Funding After Building an AI Security Community

October 13, 2026

Recommended

Guardz founders

Why Guardz Is Bringing Palo Alto Networks Prisma Browser Protection Into The MSP Security Stack

November 2, 2026
Hud Launches Agentic Rollouts to Give Coding Agents a Feedback Loop From Production

Hud Launches Agentic Rollouts to Give Coding Agents a Feedback Loop From Production

October 29, 2026
Pluto Security Emerges From Stealth With $42M in Funding After Building an AI Security Community

Pluto Security Shows Why Hugging Face Scanners Cleared a Live Malware Campaign

October 29, 2026
man sitting with legs crossed

Upwind’s $400M Series C Follows Fourfold Revenue Growth and a Jump to a $3.8B Valuation

October 28, 2026

Categories

  • AI & Robotics
  • Benzinga
  • Cybersecurity
  • FinTech
  • New York Tech
  • News
  • Startups & Leaders
  • Venture Capital

Tags

AI AI QSRs AI security Automat-it AWS B2B marketing Bloom Security Business CISO CISO Whisperer Collaborations Cybersecurity Drive-Thru Enterprise AI Entrepreneur Finance FINQ Fintech Funding Announcement Hi Auto HumanX Impala Investing Investors investorsummit israelitech Mate Security Mindset Minnesota omri hurwitz Perion Pluto Security PointFive PR QSR Real Estate Runtime Intelligence start- up startupnation Startups Tech Tech leaders Upwind Security VC venture capital
  • Contact Us
  • Privacy Policy
  • Terms and conditions

© 2024 All Rights Reserved - New York Tech Media

No Result
View All Result
  • News
  • FinTech
  • AI & Robotics
  • Cybersecurity
  • Startups & Leaders
  • Venture Capital

© 2024 All Rights Reserved - New York Tech Media